2026-10-08 · Feature
EKF takeoff, one step at a time.
A GPS-denied launch has a fixed order: the autopilot must be configured for a MAVLink GPS, the takeoff point planted, the synthetic fix streamed and echoed back, the EKF given its ten quiet seconds to accept it, and only then can anyone arm. The old dialog showed all of that at once on two tabs. The new one is a wizard: six rows, each with a verdict, the one that needs work open, the rest folded to a single line.
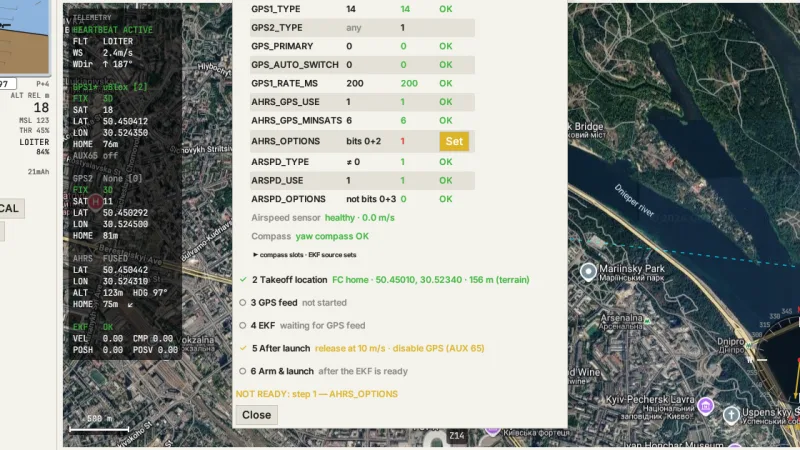
The parameter step no longer asks which GPS slot to feed. Whichever instance is set to MAVLink is the one, and the checklist pins it as primary with auto-switch off, because a real receiver with a 3D fix would otherwise silently outrank the synthetic one. It also guards the airspeed sensor: after release the EKF navigates on the pitot alone, and two ArduPilot options can switch that sensor off when its reading disagrees with a GPS that no longer exists. Those rows are red until fixed.
The EKF step is the one that matters, so it reads like a verdict: WARMING UP, keep the aircraft still, with a countdown; READY TO FLY once the filter is fusing the injected position and its variances are inside the launch limit; NOT READY with the reason when it is not. The details stay underneath for anyone who wants the flags and numbers, with ArduPilot's own aiding-mode name next to them for cross-reading with a log.
The after-launch step makes the GPS policy explicit. Disabling the receiver at release is on by default and done over MAVLink, so no radio channel has to be mapped; if one is, the wizard says so, because a physical switch overrides the command whenever it moves. Starting the feed also re-enables GPS first, so a disable left over from the previous flight cannot quietly starve the feed.
Closing the wizard stops the feed. Nothing streams behind a closed window.
Shipping in v0.19.0 · macOS / Windows / Linux